At a glance
Built to work alone
Point it at a floor and let it go. It explores unknown space on its own and builds a 3D map of everything it passes. Give it the zones that hold welds and it plans a route through them, drives itself from one to the next and scans every weld in each zone with its gimbal camera, sending the images back as it captures them. Under the hood, an AI driver sets the speed of each track about a dozen times a second, and a safety layer can always overrule it: an emergency stop, sensor watchdogs and a hard block on driving into anything.
Test runs: 200 runs at fixed difficulty in a cluttered room with partitions and alcoves, 3–5 goals each.
- Body
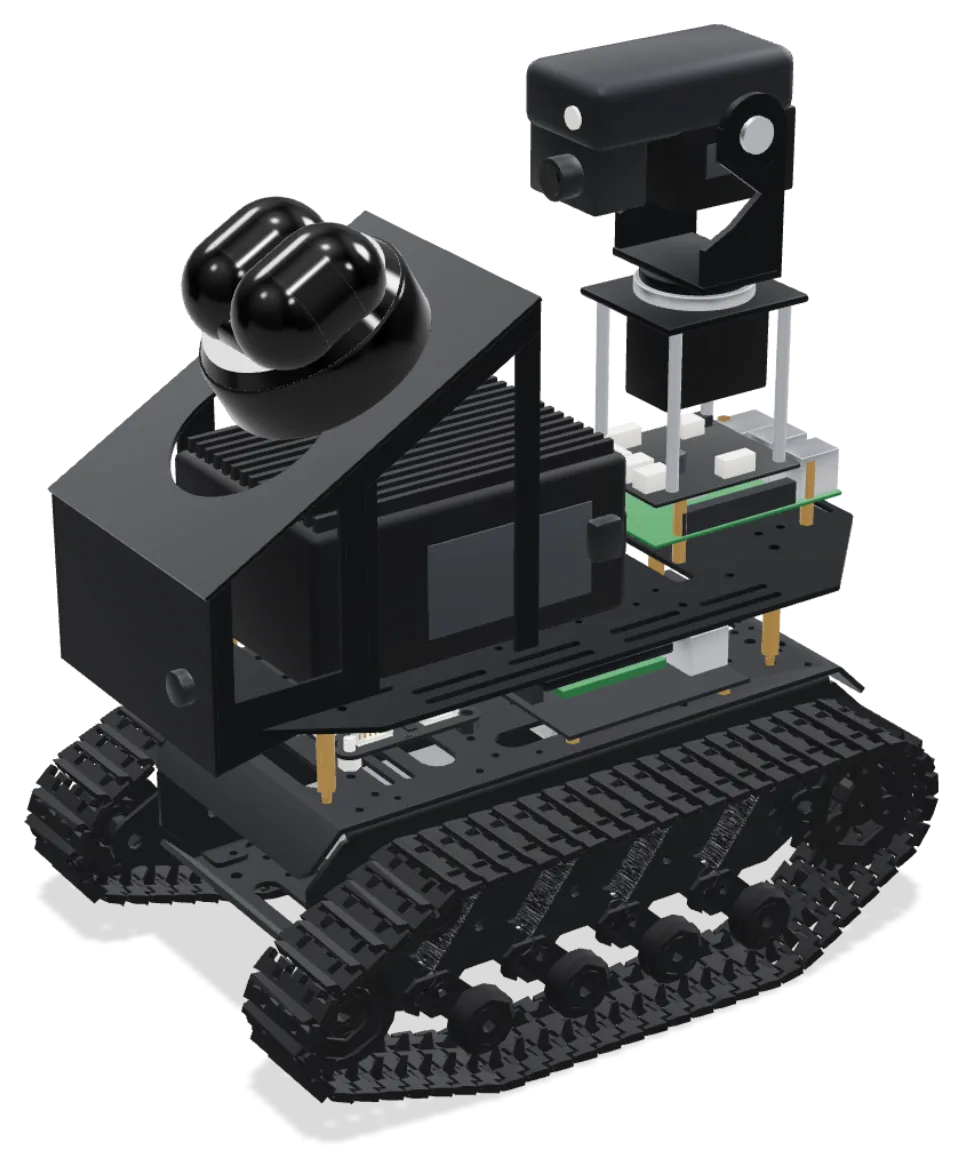
- Tracked base, 30 × 19 cmTop speed 0.36 m/s; drives at up to 0.31 m/s
- Mission
- 3D floor mapping and weld inspectionZone to zone with no operator; images are sent back as they're captured
- Senses
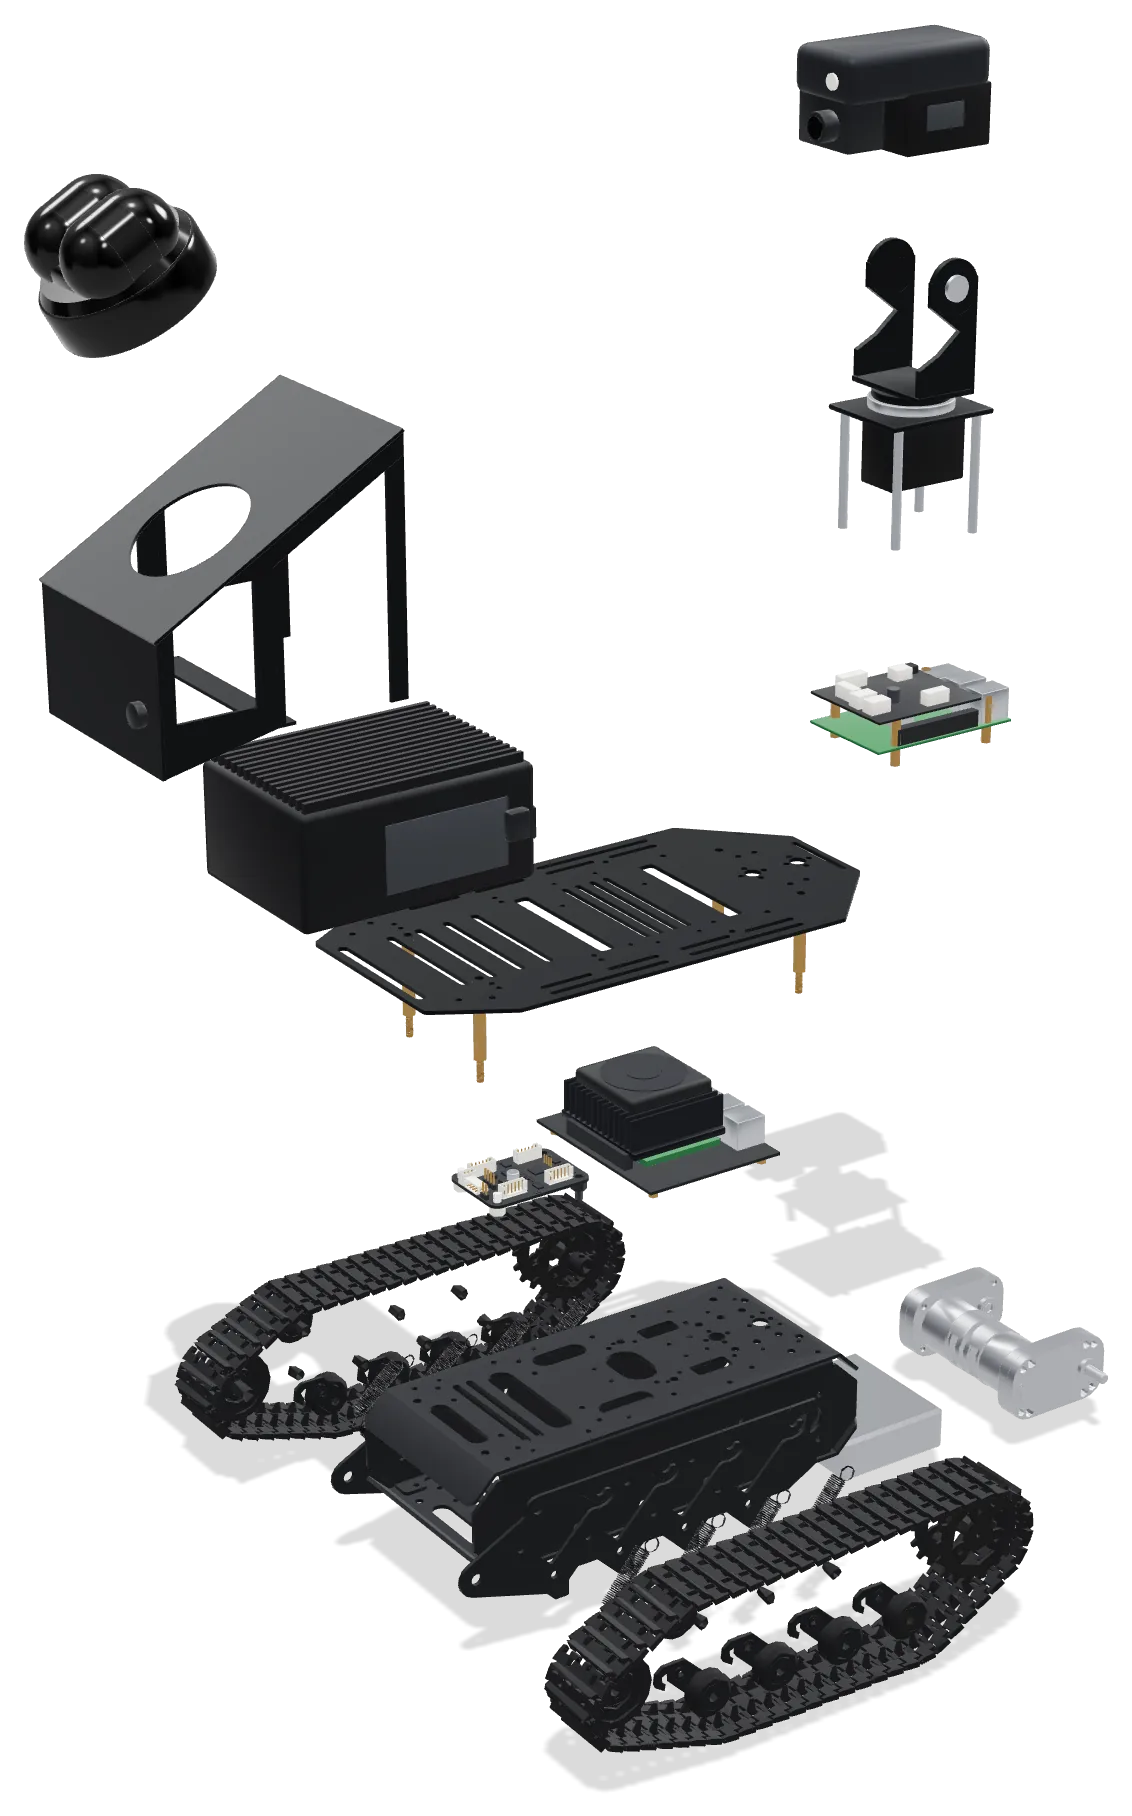
- Unitree L2 3D LiDAR and a RealSense depth cameraV2 swaps the gimbal camera for a liquid-lens inspection camera the robot aims itself
- Brain
- NVIDIA Jetson Orin Nano, on board3D mapping, planning, the AI driver, the mission and the web console all run on the robot
- Software
- Python, PyTorch, ROS 2, FAST-LIO2, YOLO11Driver trained with reinforcement learning in a GPU simulator I wrote
The journey
From a bare chassis to an autonomous inspector
-
Early August 2026
The mission: go anywhere, see everything, report back
Industrial inspection still runs on people walking the floor: checking welds, counting stock, confirming an aisle is clear. It's slow, it's repetitive, and it's exactly the kind of work a robot should own.
Underneath every one of those jobs is the same skill: reach any spot on your own, touch nothing on the way, and capture what's there. I started by prototyping an AI driver in NVIDIA Isaac Lab and testing it in a phone-scanned copy of a real room it had never trained in.
What I foundCheck the test before blaming the model. Two unfair setups in my test were hiding real progress. Fixing them tripled the prototype's score in the held-out room.
-
August 8–12
Giving it senses
I built the robot around a small tracked chassis, a 3D LiDAR on top and an NVIDIA Jetson as its brain. FAST-LIO2 fuses the LiDAR with an inertial sensor into a live map with the robot's own position on it, and a route planner finds the way to any goal on that map. On its best early run, the path it drove was only 2% longer than a straight line.
Then I hunted down the quiet bugs, the kind that produce believable output that's wrong. The LiDAR's 30° downward tilt hid obstacles from the planner. The position it reported was the sensor's, not the robot's, so every on-the-spot turn swung it by 11.6 cm. And the sensor sat 5° off the robot's axis. All three are fixed.
What I foundMeasure constants from the data, on every scan. A mounting angle I measured once had drifted by 3–4°. Fitting the floor plane on every scan fixed it for good.
-
August 13–22
Teaching it to drive
Hand-written driving rules break the moment a space gets cluttered, so the robot learns to drive instead. I wrote my own GPU simulator in PyTorch, built from the robot's measured physics: its real top speed, how far it coasts, how its tracks pivot, how late its position arrives. The AI driver practises in endlessly varied rooms, sees the world exactly as the robot does (50 LiDAR rays across the front, 13 sectors behind) and makes a decision about 12 times a second.
Every training run has to earn its compute. Before one starts, a scripted expert driver must pass the same test. If a hand-built driver can't do the task, a learned one won't either, so the gate catches a broken task before it wastes a run.
What I foundWhere training settles is a design choice. Letting practice rooms outgrow the driver's skill made it bump into things in 77% of runs. Capping the difficulty cut that to about 17% and produced the driver that runs on the robot today.
-
August 23–24
Crossing from simulation to reality
On the real robot, the driver that aced the simulator spun in circles, turning up to 439° for every metre it drove. Rather than retrain and hope, I recorded everything the robot sensed and compared it, channel by channel, with what it saw in simulation.
Five faults surfaced, one after another. Its sense of its own turning was estimated from its commands rather than measured, and its position arrived about 300 ms late. The mapping software deleted everything within 30 cm. Phantom obstacles caged it inside its own map. Part of the obstacle sensing read the carpet as an obstacle 90% of the time. And the route planner was hogging the control loop, so for two-thirds of the drive the AI driver wasn't running at all.
With the carpet fixed, it reached 38% of its goals. With the planner fixed too, the same trained driver reached 100% of them that afternoon. No retraining.
What I foundA planner on the control thread is a driver that isn't running. The simulator plans in zero time; the real robot doesn't. Moving the planner to its own thread did more than any retrain could have.
-
August 25 – September 2
Training for the spaces it actually works in
The real test space was a corridor 2.44 m wide, but the narrowest practice room in the simulator was 3 m, so not one training room looked like the place it actually had to drive. I added rooms down to 1.8 m wide, taking corridor-width rooms from 0% of practice to 29%.
I also moved the robot's safety layer, and its habit of clearing map cells it has driven over, into the simulator, so the driver practises under the exact rules it lives by.
What I foundPut every input from a real drive next to the same input from simulation. That one habit exposed both the carpet problem and the corridor gap.
-
September 3–6
Seeing in 3D
With driving solid, I gave it better eyes. A RealSense depth camera adds colour 3D, and the LiDAR builds a live 3D map that erases things once they've moved away. A box detector trained on about 53,000 images from 27 datasets finds boxes with 93% mAP50 on held-out images. Frames from the robot's camera can also be rebuilt into a photo-realistic 3D model of the space (a Gaussian splat) that you can explore on a phone.
All of it runs from a web console the robot serves itself. Tap a spot to send it there, drive with a thumb joystick, fence off keep-out zones, let it explore unknown space on its own, and save maps by name for later missions.
-
September 2026
Aiming its own camera
The newest driver steers a pan-tilt gimbal as well as the tracks, so it decides where to look while it drives. In a harder narrow-corridor test it reaches every goal in 93.8% of runs.
Building it also exposed a bug that had been hiding in the simulator for two weeks: its map-clearing was mirrored. Fixing it lifted the scripted expert from 71.6% to 85.9% on a harder test level. The new driver is now being tuned on real floors.
What I foundA test that shares a bug's assumptions can't see the bug, and a test that doesn't exist never fails.
-
Now
Inspecting welds on its own
Everything above comes together in one mission. The robot explores the warehouse and maps the entire floor in 3D. Then it works through every zone that holds welds: it drives itself to the zone, sweeps the gimbal across each weld, captures it and sends the images back, then moves on to the next zone. Zone after zone, unsupervised.
The camera is built for the job. The V2 build carries a machine-vision box camera with a liquid lens. Instead of a motor sliding glass back and forth, a voltage reshapes the lens itself, so focus jumps from one distance to the next in milliseconds. As the gimbal swings between welds near and far, every image is already sharp.
Missions
One robot, many missions
Reaching any spot on its own, avoiding everything in the way and capturing what's there is a universal skill. Weld inspection is where it starts.
On the robot Tested in software Next
- On the robotWeld inspection, zone to zone
Drives itself to each zone with welds to inspect, scans every weld with the gimbal camera, sends the images back and moves on to the next zone.
- On the robotMap an entire floor in 3D
Explores unknown space on its own and builds a 3D map of the whole floor, saved for later missions or rebuilt as a photo-realistic 3D model.
- On the robotDrive to any spot and scan
Pick a spot on a saved map. It plans the route, drives there around whatever is in the way and captures a colour 3D scan of what it finds.
- On the robotRemote inspection
Drive it by hand from a phone to check a spot that's hard to reach or unsafe to walk to.
- Tested in softwareFind and inspect boxes
The detector spots boxes, the robot places each one on its map, plans views of up to five sides and drives to each.
- Tested in softwareGesture commands
"Follow me", "point to go", "scan and store" and "stop", read from a person's hand and body pose.
- NextInventory cycle counts
Drive a route of shelves on a schedule, read each label or barcode and reconcile the counts with the inventory system.
- NextAisle and safety patrols
Walk the floor after hours and log blocked aisles and exits, spills and pallets left in walkways.
- NextBeyond the warehouse
Weld and structural inspection in factories, shipyards and construction sites, rack audits in data centres, out-of-stock checks in retail, supply runs in labs and hospitals, and overnight security rounds.
What's next
Where it's going
Still in progress
I'm still building this
AMR is an active build. These are the next milestones, and this page will grow as they land.
- Grade each weld on the robot itself, flagging defects the moment they're captured.
- Feed the depth camera into driving and route planning, so it catches low and thin obstacles the LiDAR can miss.
- Handle moving obstacles: people, carts and forklifts crossing its path.
- Run box-finding, gesture commands and label reading on the real robot, for full inventory counts on its own.
- Navigate a whole building, room to room and zone to zone, from saved maps.
- Make full-length missions as dependable as the short tests.
Expect further improvements and changes to this project as it develops.